
 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | Bosch Rexroth Indramat |
| Model | MKD090B-047-GP0-KN |
| OEM ordering number | R911263529 |
| Motor type | Three-phase permanent-magnet synchronous servo motor |
| Frame size / length | 090 / B |
| Winding code | 047 |
| Continuous standstill torque | 12.0 Nm at 60 K temperature rise |
| Continuous standstill torque, 100 K rise | 14.0 Nm |
| Continuous standstill current | 16.5 A |
| Peak current | 59.4 A |
| Peak stall torque | 45 Nm |
| Maximum speed | 5,000 rpm |
| Rated speed | 3,500 rpm |
| Rated torque | 9.9 Nm |
| Rated voltage | 351 V |
| Torque constant | 0.73 Nm/A |
| Winding resistance | 0.69 Ω |
| Winding inductance | 10.1 mH |
| Feedback | Resolver, relative position feedback |
| Holding brake | None |
| Shaft | Keyed shaft per DIN 6885-1 with shaft sealing ring |
| Flange size | 140 mm |
| Centering diameter | 110 mm |
| Connection | Connection box, Side B |
| Cooling | Natural convection |
| Ingress protection | IP65 motor housing; IP54 feedback connector |
| Insulation class | F |
| Ambient temperature | 0 to +40°C |
| Storage temperature | −25 to +70°C |
| Weight | 14 kg |
The values above are based on the published MKD project-planning data and supplier specifications for this exact type code.
Product Introduction
The Bosch Rexroth MKD090B-047-GP0-KN is a brushless permanent-magnet synchronous servo motor for machine-tool axes, packaging equipment, printing machinery, and high-dynamic positioning applications. Its 047 winding delivers 12.0 Nm continuous standstill torque, 45 Nm peak torque, and up to 5,000 rpm.
The GP0-KN configuration uses resolver feedback, a keyed sealed shaft, and no holding brake. It is a strong fit for horizontal or mechanically braked axes, but it is not a direct replacement for a GP1 brake-equipped motor on a vertical load without adding external braking.
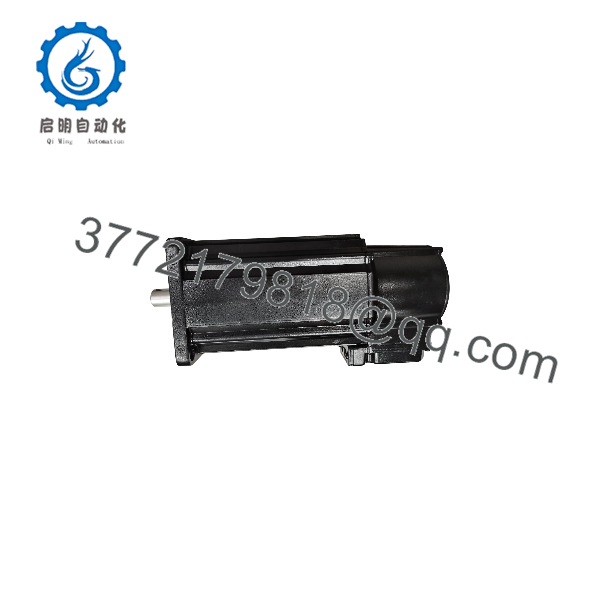
MKD090B-047-GP0-KN
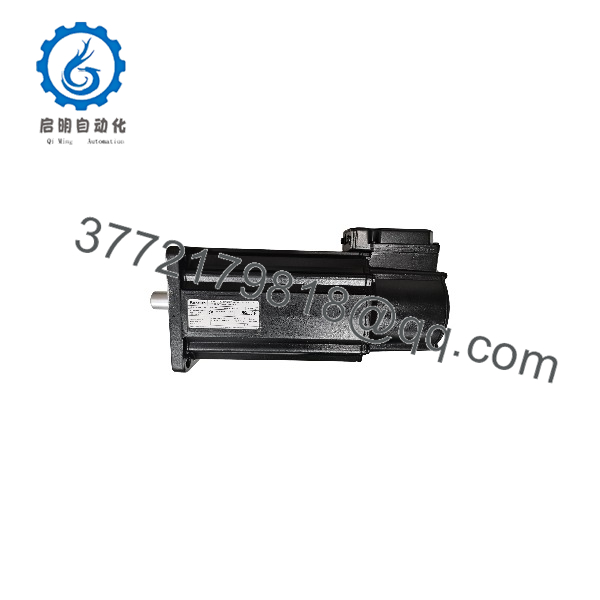
MKD090B-047-GP0-KN
Troubleshooting Quick Reference
| Symptom | Possible Cause | Relevance to this Part | Quick Check Method | Recommendation |
|---|---|---|---|---|
| Drive reports resolver or feedback fault | Damaged feedback cable, loose connector, broken shield, or resolver failure | ✅ High | Inspect and reseat the feedback connector; check cable continuity and shield termination; substitute a known-good cable | Replace the cable first; replace the motor only if the fault follows the motor |
| Motor will not develop torque | Incorrect drive motor type code, phase wiring error, or damaged power cable | ✅ High | Verify the drive motor type is MKD090B-047-GP0-KN; measure U/V/W continuity and insulation to ground | Correct the drive configuration and power wiring before condemning the motor |
| Motor overheats or trips thermal protection | Excessive duty cycle, blocked cooling, mechanical binding, or high ambient temperature | ⚠️ Medium | Measure housing temperature; review drive current/torque trend; inspect coupling and load for drag | Reduce duty cycle or load, clean cooling surfaces, and verify free mechanical travel |
| Position error or unstable operation | Coupling misalignment, loose mounting, feedback noise, or incorrect drive tuning | ⚠️ Medium | Check flange bolts and coupling runout; review following error and diagnostics in the drive | Correct mechanics and shielding before changing servo gains |
| Motor runs roughly at low speed | Incorrect commutation angle, resolver signal issue, or mechanical disturbance | ✅ High | Run the drive’s commutation/feedback diagnostic; test uncoupled only with the load safely secured | Recommission commutation and verify resolver signals; do not replace the motor first |
| Unexpected movement after power loss | No holding brake in this GP0 configuration | ✅ High | Check whether the axis is vertical or back-drivable; inspect external brake or counterbalance | Use an external mechanical brake or specify a GP1 brake-equipped variant for vertical loads |
| Bearing noise or excessive vibration | Bearing wear, shaft overload, or misalignment | ⚠️ Medium | Rotate the shaft with power removed; check radial/axial play and listen at the bearing end | Correct alignment and shaft loading; replace the motor if bearing damage is confirmed |
If the fault remains, send the Rexroth drive diagnostic list, motor nameplate photo, cable part numbers, and a short fault video to technical support before ordering a replacement.
Frequently Asked Questions
Can I hot-swap the MKD090B-047-GP0-KN?
No. Disable the servo drive, remove mains and 24 V DC control power, and allow the DC bus to discharge before disconnecting power or resolver cables. This motor has no holding brake, so secure any movable load first.
Does this motor include a holding brake?
No. The GP0 suffix means no holding brake is installed. Do not use it as a direct replacement for a GP1 motor on a vertical axis unless an external mechanical brake is already fitted.
Is the resolver absolute or incremental?
The KN configuration uses resolver feedback for relative position and commutation. It does not include the integrated multiturn absolute encoder used in KG1 versions.
Can I replace it with an MKD090B-047-GP1-KN?
Not without reviewing the application. The GP1 version adds an 11 Nm holding brake and requires brake-supply wiring, drive configuration, and mechanical clearance checks. The 090B frame and 047 winding match, but the complete type code must be verified.
Which Rexroth drives work with this motor?
MKD motors are used with Rexroth Indramat DDS, DKS, DKC, HDS, and HDD servo drive families. Confirm that the installed drive supports the 047 winding and resolver feedback before ordering.
Why is the rated torque lower than the standstill torque?
The 9.9 Nm rated torque applies at 3,500 rpm, where thermal and back-EMF limits reduce available continuous torque. The 12.0 Nm value is the continuous standstill torque at a 60 K winding temperature rise.
What condition is this motor supplied in?
This is New Original / New Surplus stock, not used or refurbished. Each unit is inspected, function-tested, and shipped in ESD-safe packaging with a test report; photos and test documentation are available on request.



