
 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | Bosch Rexroth AG (Indramat product line) |
| Material Number | R911310527 |
| Series / Type | MSK101, IndraDyn S synchronous servo motor |
| Frame Size / Length | 101 / length D (longest stack in frame) |
| Winding Code | 0200 |
| Pole Count | 4-pole |
| Max Speed | 3400 rpm |
| Standstill Torque (continuous) | 57.0 Nm (natural convection) |
| Continuous Current at Standstill | 26.8 A |
| Peak Torque | 160.0 Nm |
| Maximum Current | 99.9 A |
| Torque Constant | 2.48 Nm/A |
| Encoder (code “M1”) | Optical multiturn absolute encoder (Hiperface-class), 128 signal periods |
| Holding Brake (code “G2”) | Electrically releasing holding brake, 70 Nm |
| Shaft | Plain shaft, shaft seal ring included |
| Power Connector (code “A”) | A-side connector orientation |
| Cooling | Natural convection |
| Degree of Protection | IP65 |
| Insulation Class | F (per DIN EN 60034-1) |
| Temperature Monitoring | KTY thermal sensor in winding (drive-side evaluation) |
| Ambient Temperature | 0 to +40 °C |
| Approx. Weight | approx. 40 kg (length D with brake — verify exact value on datasheet) |
⚠️ Verify precise electrical limits, continuous torque at 60 K/100 K ratings, and exact mass against the official Rexroth datasheet for R911310527 before installation. This motor requires a drive sized for near-100 A peak current — that constraint drives the whole application review, not the torque number.
Product Introduction
The Bosch Rexroth MSK101D-0200-NN-M1-AG2-NNNN (R911310527) is an IndraDyn S synchronous AC servo motor in the largest standard MSK frame — 101, length D. With 57 Nm continuous torque and 160 Nm peak at up to 3400 rpm, this motor class handles heavy gantry axes, large rotary tables, presses, extruder and mixer drives, and machining axes that smaller frames simply cannot turn. The 2.48 Nm/A torque constant means it gets there without the extreme currents of lower-class windings.
The M1 encoder is an optical multiturn absolute unit with 128 signal periods, holding absolute position through power cycles with no homing routine after every restart. The G2 option adds a 70 Nm electrically releasing holding brake on a plain shaft — sized for serious gravity-loaded axes — and the A-code places the power connector on the A side for machines where cable routing comes in from the frame. The motor pairs with Rexroth IndraDrive and legacy Indramat drive platforms with optical multiturn encoder support. Match the drive and cable set carefully: at 99.9 A peak, an undersized drive, wrong encoder cable, or a brake supply that can’t deliver release current will all show up as faults — or worse, as heat — within the first shift.
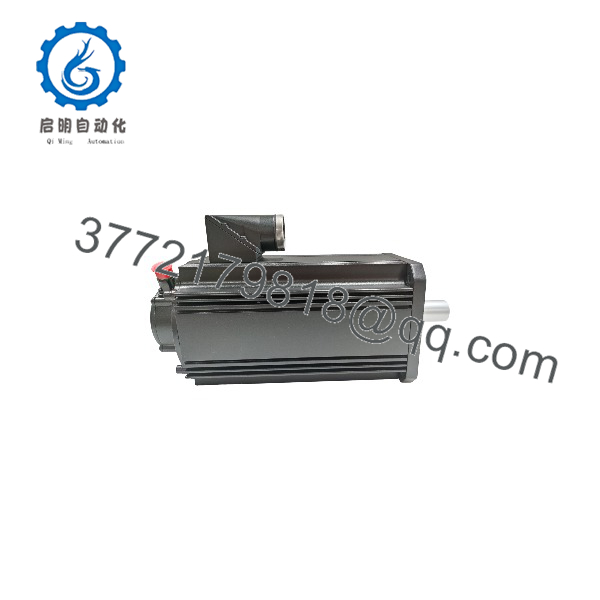
MSK101D-0200-NN-M1-AG2-NNNN
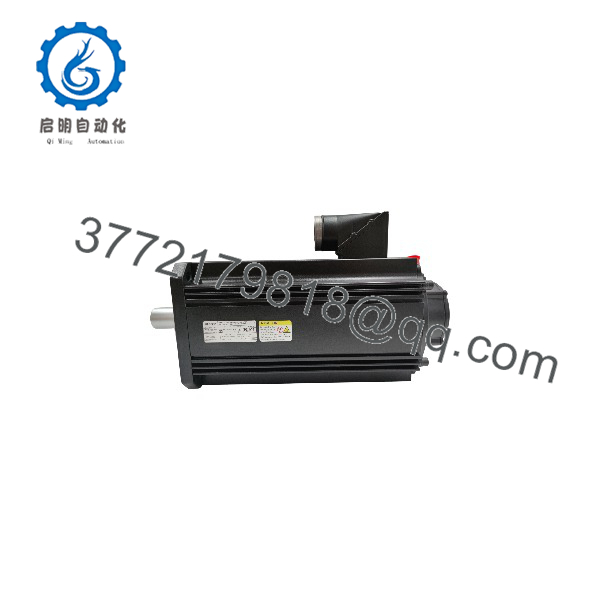
MSK101D-0200-NN-M1-AG2-NNNN
Installation & Configuration Guide
Total estimated time for a two-person crew: 2–3 hours, plus drive commissioning, homing, and full mechanical alignment.
Stage 1: Pre-Installation Preparation (30 min)
⚠️ Safety First: This is a 40 kg motor holding an axis that may weigh hundreds of kilograms. Notify operations, move the axis to a safe position, and mechanically block the load before anything else. The 70 Nm brake is a functional brake — it releases when power drops, and on a vertical or gravity-biased axis, whatever it was holding becomes a moving hazard. Lock out/tag out drive power, wait 5 minutes minimum for DC bus discharge (large drives store real energy), and verify zero voltage before touching connectors.
Tools Required:
- Grounded ESD wrist strap
- Hex key set and torque wrench
- Lifting equipment rated for 40+ kg and a second person — a length-D 101 frame motor cannot be safely muscled into a flange one-handed
- Multimeter and 500 V insulation tester
- Label tape, dial indicator, smartphone for photos
Data Backup:
- Photograph the old nameplate, connector orientations (A-side matters), and coupling seating.
- Back up the drive’s motor parameter set and fault log via IndraWorks / DriveTop or the legacy HMI.
- Record the axis home offset and position — the new multiturn encoder’s reference will differ.
- Confirm the encoder cable matches the M1 optical multiturn interface including the backup path, and that the power cable is sized for 99.9 A peaks — undersized cable at this current class is a fire path, not a nuisance fault.
Stage 2: Removing the Old Motor (30–45 min)
- Confirm the load is mechanically blocked. Disconnect power and encoder connectors; label both cables at both ends.
- Rig the motor’s lifting points before removing flange bolts. Never let a 40 kg motor hang off a half-unbolted flange or rest on its shaft.
- Withdraw the motor straight back off the coupling. Do not lever against the shaft or the brake housing.
- Inspect the coupling, flange face, and any residue. On 160 Nm-class axes, coupling wear and fretting at the flange are the norm rather than the exception past 40,000 running hours — check the mechanics before installing the replacement, or you’ll be repeating this job.
- On natural-convection motors, check the cooling ribs for caked dust. A new motor bolted into an air path blocked by contamination runs hot from day one.
⚠️ Note: Keep the old motor on the bench until the new one completes a full production cycle. MSK 101 comes in A through D lengths with very different torque ratings — compare the full nameplate, not the frame size.
Stage 3: Installing the New Motor (45 min)
- Ground yourself before handling the connectors. ESD to the encoder board kills more MSK motors than field wear does.
- Verify the nameplate matches exactly: MSK101D-0200-NN-M1-AG2-NNNN, material number R911310527. Length “D”, winding “0200”, encoder “M1”, brake “G2” with plain shaft, and A-side power connector. A “B” or “C” length delivers meaningfully less torque; a BG2 variant moves the connector to the B side, which may not match your cable routing; a keyway variant won’t fit your plain-shaft coupling.
- Mount the motor with the lifting aid; torque flange bolts per the MSK 101 mounting drawing in a cross pattern.
- Dial-indicate the coupling. At 160 Nm peak, misalignment doesn’t just wear bearings — it hammers the coupling loose and hammers your foundation bolts loose with it.
- Connect power and encoder cables; rotate housings for routing, hand-tight only.
- Brake wiring: the 70 Nm brake draws a real release current. Verify the 24 V supply sizing and the drive’s brake-control output rating against the datasheet. An undersized brake supply on this frame doesn’t just drag — a partially engaged 70 Nm brake at speed generates enough heat to damage the brake and the bearing plate.
Self-Checklist:
- Nameplate matches R911310527 exactly
- A-side connector orientation matches cable routing
- Coupling alignment dial-indicated
- Power cable sized for 99.9 A peak
- Encoder cable matches M1 multiturn interface
- Brake supply verified for release current
- Both connectors seated and locked
Stage 4: Power-Up & Testing (30–45 min)
Pre-Power Check:
- Phase-to-phase resistance on U/V/W, balanced within a few percent; log the values.
- Insulation test phase-to-ground at 500 V DC, >10 MΩ. Fully disconnect the drive power stage before meggering — this rule matters more at 99.9 A drive ratings than anywhere else.
- Verify the KTY sensor reads plausibly at ambient through the drive.
- Check encoder shield clamping at both ends and verify the cable runs are separated from motor power runs.
Power-On Steps:
- Control power to the drive first, before enabling power electronics.
- Power up and check for encoder communication faults and brake feedback faults.
- Confirm the drive reads the motor’s digital type plate. A motor-data mismatch means a variant difference — stop and compare nameplates before enabling torque.
- Brake test: enable, command brake release, and listen for a clean clack from the brake. Verify full release by jogging at low speed — any drag, buzz, or heat means supply problems. Power down before investigating.
- Jog at low speed both directions, no load. Confirm smooth rotation, no hunting, no unusual acoustic noise.
- Torque-ramp test: increase load in steps toward normal duty while watching the KTY temperature readout and drive current. A natural-convection 101D at sustained high torque needs the full rib surface in open air — anything past rated temperature at moderate duty means blocked airflow, brake drag, or a mechanical bind.
- Re-home the axis, run one reduced-speed cycle, then one full-speed cycle with someone watching the coupling and mounting bolts.
⚠️ Troubleshooting Note: Encoder comms faults point to cable or connector; motor-data mismatch points to a wrong variant; overcurrent trips at moderate load point to a drive current limit set below the application’s demand or a genuine mechanical bind. On a 70 Nm brake, a motor that trips on overtemperature at low speed with modest load almost always has a dragging brake — measure the brake supply voltage under load, not just at the panel.
Frequently Asked Questions (FAQ)
Q1: Can I hot-swap this motor with the drive powered up?
Absolutely not, at this frame size more than any other. Live-disconnecting the encoder risks the encoder board and the drive’s feedback channel — and this drive class is expensive. But the real hazard is mechanical: a 70 Nm brake holding a heavy axis releases the moment its power drops. On a vertical axis or biased gantry, that axis moves with hundreds of kilograms behind it. Full LOTO, full bus discharge, mechanical blocking, two people, lifting equipment. There is no version of this swap that is worth rushing.
Q2: Is the MSK101D still a current product, and is this unit genuinely new?
The MSK series is still active, but large-frame material numbers like R911310527 are supplied increasingly from surplus stock as factory production shifts toward the newer MSM/MST lines. Our stock is New Original / New Surplus: factory packaging, intact nameplate and digital parameter memory, verified against the OEM datasheet. Units that have been powered before are sold as tested refurb at a lower price, labeled as such — no gray areas. Test photos and the bench report are available on request.
Q3: What can I substitute if R911310527 is out of stock?
Within MSK 101, the nearest equivalents keep the “0200” winding and “M1” encoder: the BG2 variant if A-side vs B-side connector orientation works with your routing (verify before ordering — it’s the difference between a clean install and a cable that won’t reach), or the AG0 if your axis doesn’t need a brake. Do not drop to a “C” length without checking the numbers — the torque step between lengths in the 101 frame is substantial, and this motor is usually installed because the application needed every newton-meter. Different winding codes change drive current and voltage-constant settings; encoder-family swaps require full feedback re-commissioning. Send us your drive type and axis duty cycle and we’ll tell you honestly whether a variant works or you need this exact material number.
Q4: Will I lose my program or position data when I swap the motor?
The drive program stays in the drive. The M1 multiturn absolute encoder means the new motor reports absolute position immediately, but its reference differs slightly from the old motor’s — re-home once, record the offset, done. If the axis loses absolute position after every power cycle post-swap, the multiturn backup path in the encoder circuit is broken; fix that before condemning a healthy motor. On a machine this size, budget time for the re-home — some gantry homing routines move serious mass and should be done at creep speed the first time.
Q5: What will the 70 Nm holding brake actually hold?
70 Nm of friction holding torque at the motor shaft, drive disabled. Direct-drive, that’s 70 Nm static. Through a gearbox, multiply by ratio and efficiency — a 30:1 planetary at 90% gives roughly 1,890 Nm at the output, minus margin for pad wear. It’s a functional brake: holding force decays over life, it’s not safety-rated for personnel protection (that requires a safe-hold variant plus an ISO 13849 assessment), and during maintenance it should never be trusted alone. The brake holds the axis; mechanical blocks protect the people. Use both.
Q6: Why is your price below the Rexroth factory list price?
Surplus stock skips fresh-production lead time, distribution markup, and OEM support overhead. Same factory-built motor; we carry the 1-year warranty ourselves. At this frame size the factory lead time can stretch into months, and OEM list price on a length-D 101 runs high — for a dead high-torque axis, tested stock shipping in days usually ends the conversation. For new machine builds where consolidated OEM warranty matters, the factory channel can still make sense. We’ll tell you which situation you’re in.
Q7: Do you test the motor before it ships?
Every unit gets a live functional test on a Rexroth IndraDrive test bench rated for this frame: power-up, encoder communication and position readout, phase-to-phase resistance balance, 500 V insulation test (>10 MΩ), KTY sensor verification, brake release/engage at rated voltage, and a continuous run to thermal stability. Results are recorded on a test report available on request. No honest engineer will call any motor “100% failure-proof” — what we claim is simpler: verified fully functional under load testing before it leaves our bench.



