WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | KEB, Karl E. Brinkmann GmbH |
| Model | A3.SM.000-62DY |
| Series | SM Synchronous Servo Motors |
| Product Type | Three-phase synchronous servo motor |
| Primary Application | Industrial motion control and automated machinery |
| Listed Rated Output | 2.0 kW |
| Listed Rated Voltage | 400 V |
| Listed Rated Current | 11 A |
| Listed Rated Speed | 3,000 RPM |
| Listed Continuous Torque | Approximately 6.37 Nm |
| Supply Frequency | 50/60 Hz |
| Cooling Method | Air-cooled |
| Feedback Device | Incremental encoder listed; verify actual nameplate and connector |
| Protection Rating | IP54 listed |
| Mounting Arrangement | B3 listed |
| Listed Operating Temperature | −20 to +40 °C |
| Reported Weight | Approximately 15 kg |
| Reported Dimensions | Approximately 300 × 150 × 100 mm |
| Compatibility Requirement | Must be matched to the correct KEB servo drive, feedback interface, motor cable, and motion parameters |
The available part-specific sources identify A3.SM.000-62DY as a KEB SM-series synchronous servo motor. Multiple sources report 2.0 kW, 400 V, and 3,000 RPM, while the detailed technical listing also reports 11 A, approximately 6.37 Nm continuous torque, IP54, B3 mounting, and incremental encoder feedback. Verify every electrical and mechanical value from the actual motor nameplate and KEB documentation before installation.
Product Introduction
The KEB A3.SM.000-62DY is a three-phase synchronous servo motor in the KEB SM motor family. It is used with a compatible servo drive for closed-loop motion control in automated machinery, including positioning, controlled-speed operation, and torque-regulated axis applications. Available records list a 2.0 kW, 400 V, 3,000 RPM configuration.
This motor should be sourced as an exact motion-axis replacement. The correct unit must match the installed drive, feedback connector, encoder type, motor cable, flange, shaft, brake configuration, inertia requirements, and parameter set. A similar KEB motor may bolt up physically but still create encoder, commutation, overspeed, or torque-control faults.
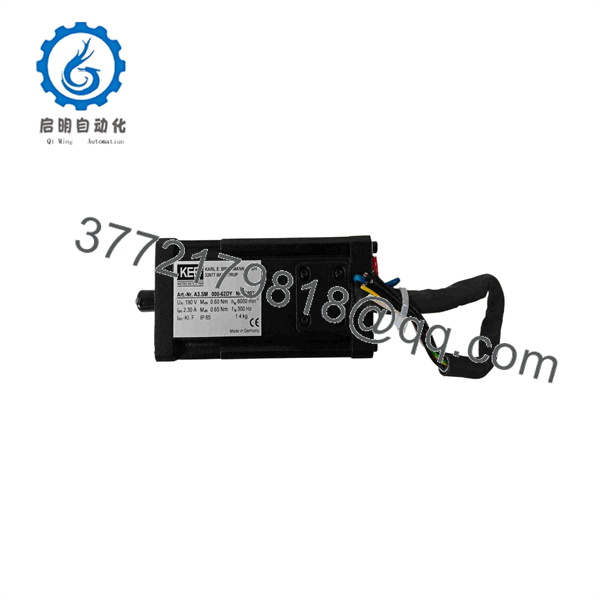
A3.SM.000-62DY
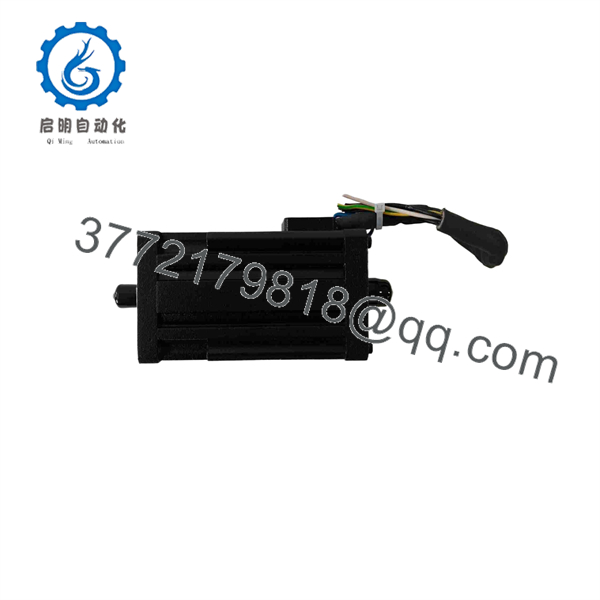
A3.SM.000-62DY
Troubleshooting Quick Reference
| Symptom | Possible Cause | Relevance to This Part | Quick Check Method | Recommendation |
|---|---|---|---|---|
| Servo drive faults immediately at enable | Encoder connection fault, incorrect motor parameters, phase wiring error, brake not releasing, drive fault | ⚠️ Medium | Review the drive fault code; inspect encoder and motor-power connectors; compare installed motor data with the configured drive parameters | Verify motor identification and feedback before replacing the motor |
| Motor does not rotate | Safety circuit open, servo not enabled, brake engaged, missing DC bus, disconnected motor cable, mechanical jam | ⚠️ Medium | Confirm drive enable, safety status, DC bus, brake-control output, and motor connector seating | Check controller and mechanical conditions before condemning the motor |
| Motor hums or vibrates without motion | Incorrect phase sequence, encoder fault, incorrect commutation data, seized load, loose coupling | ✅ High | Isolate power, inspect coupling and load movement, review drive diagnostics, and compare motor parameter file | Do not continue enabling the axis until wiring and feedback are verified |
| Motor runs but position is incorrect | Encoder failure, damaged feedback cable, coupling slip, incorrect encoder scaling, parameter mismatch | ✅ High | Compare commanded and actual position in the drive diagnostics; inspect encoder cable and coupling fasteners | Verify feedback signal and mechanical coupling before replacing the motor |
| Repeated following-error faults | Excessive load inertia, mechanical binding, insufficient tuning, encoder noise, reduced motor torque | ⚠️ Medium | Review torque demand, following error, speed trace, and axis mechanics; check cable shielding and encoder feedback | Investigate load and tuning before replacing the motor |
| Motor overheats | Excessive continuous torque demand, restricted cooling, high ambient temperature, bearing damage, incorrect drive tuning | ✅ High | Measure motor surface temperature using an approved method; review torque trend and inspect cooling airflow | Reduce load or correct cooling; replace only after checking bearings and winding condition |
| Drive reports overcurrent | Shorted winding, damaged motor cable, seized gearbox, jammed mechanism, failed drive output stage | ✅ High | With power isolated and capacitors discharged, measure phase-to-phase resistance and insulation according to the OEM procedure | Check the motor cable and driven mechanics before installing a replacement |
| Noise, vibration, or bearing growl | Bearing wear, shaft damage, misalignment, loose pulley or coupling, mechanical resonance | ✅ High | Rotate shaft by hand only when safely disconnected; inspect coupling alignment and listen for bearing noise during controlled testing | Repair mechanical issues before replacing the motor |
| Fault begins after motor replacement | Wrong feedback type, wrong encoder connector, incompatible drive parameters, brake wiring error, incorrect motor orientation | ✅ High | Compare old and replacement nameplates, shaft, flange, feedback connector, power connector, brake wiring, and parameter file | Stop commissioning until all differences are resolved |
Field warning: Servo motors rarely fail without a reason. A seized gearbox, jammed ballscrew, overtightened belt, damaged feedback cable, bad drive output stage, or poor tuning can destroy the replacement motor. Check the entire axis before applying power.
❗ Do not confuse this motor with an encoder interface module: One low-quality marketplace page calls A3.SM.000-62DY an encoder interface module, while the actual part-specific listings identify it as a KEB synchronous servo motor. Do not use controller-module wiring assumptions or I/O test methods on this motor.
❗ Feedback matching comes first: Confirm the encoder technology, connector type, pinout, resolution, commutation method, and drive parameter file. A wrong feedback setup can create uncontrolled motion, following errors, overcurrent trips, or immediate encoder faults. Photograph the original motor connector and nameplate before removal.
❗ Do not use a generic VFD as a test drive: This is a synchronous servo motor intended for closed-loop operation with a compatible servo amplifier and feedback circuit. A general-purpose VFD may not recognize the feedback device, commutate the motor correctly, or enforce the required current and motion limits.
❗ Brake configuration must be verified: Do not assume every A3.SM.000-62DY has the same holding brake configuration. Verify brake presence, coil voltage, wiring, release logic, and machine safety requirement from the actual nameplate and equipment drawings before ordering.
❗ Mechanical fit is only half the job: Verify shaft diameter and length, keyway, flange pilot, bolt pattern, overall length, coupling geometry, and cable exit orientation. I have seen a motor with the right electrical rating become useless because the rear encoder connector hit the machine guard.
❗ Insulation testing requires care: Do not apply a megohmmeter to encoder, resolver, temperature-sensor, or brake circuits. If insulation testing is required, isolate the appropriate motor power terminals and follow KEB’s approved service procedure. Incorrect test voltage can damage low-voltage feedback electronics.
❗ ESD and cable handling: Use a grounded wrist strap around encoder connectors and drive electronics. Keep encoder cables separate from motor power cables where the machine design permits, maintain shielding, and never pull the motor by its cable.
Keep these checks in mind and you will save yourself 90% of typical rework time. If the fault remains unclear, send technical support photos of the nameplate, shaft and flange, power and feedback connectors, servo-drive fault code, motor parameters, and a trend showing commanded versus actual position.
Frequently Asked Questions
What is the KEB A3.SM.000-62DY?
The KEB A3.SM.000-62DY is an SM-series synchronous servo motor for industrial motion-control applications. Available sources identify it as a three-phase motor used with a compatible KEB servo drive, with listed ratings of 2.0 kW, 400 V, and 3,000 RPM.
Is A3.SM.000-62DY a servo motor or an encoder interface module?
It is a servo motor. Marketplace records include one incorrect “encoder interface module” description, but multiple part-specific listings identify the item as a KEB SM synchronous servo motor. Do not buy it as a PLC card, feedback module, or drive interface board.
What servo drive works with this motor?
Use the exact compatible KEB servo drive and parameter set specified by the original machine builder or KEB documentation. The motor must match the drive’s voltage class, current capability, feedback type, encoder resolution, commutation data, brake wiring, and tuning requirements. Do not select a drive from the power rating alone.
Can I replace it with A3.SM.001-62DY?
Not without checking the complete nameplate and OEM cross-reference. A3.SM.001-62DY is a distinct KEB model designation. A small suffix difference may change encoder feedback, shaft, mounting, brake, winding, cable exit, thermal sensor, or motor parameters. Match the full number A3.SM.000-62DY before approving a replacement.
Can I hot-swap the servo motor?
No. Shut down the axis, isolate the servo drive, apply lockout/tagout, wait for the DC bus to discharge, and verify the absence of hazardous voltage before disconnecting motor power, feedback, brake, or grounding conductors. The motor can move unexpectedly if control power or stored energy remains present.
Does the motor have an encoder?
Detailed market data lists an incremental encoder, but that must be verified on the actual unit. The feedback type and connector are critical for replacement compatibility. Check the nameplate, connector labels, motor cable, original drive configuration, and machine electrical drawings before ordering.
Does the motor have a holding brake?
Do not assume it does. The publicly available listings retrieved here do not reliably establish the brake option for every A3.SM.000-62DY unit. Confirm the brake marking on the motor label, brake cable presence, brake coil specification, and machine safety design. A vertical axis without the correct brake can drop when power is removed.
What does the 2.0 kW rating mean for replacement?
The 2.0 kW rating is only one part of motor selection. The replacement must also match voltage, rated current, rated speed, torque curve, inertia, shaft, flange, feedback, brake configuration, environmental protection, cooling, and compatible drive parameters. A 2.0 kW motor with the wrong encoder can fault immediately even if the flange fits.
Is KEB A3.SM.000-62DY obsolete?
Treat it as a legacy KEB motion-control spare. Current availability appears to come mainly from surplus, used, or independent automation suppliers. Listings include units with cut or damaged cables, so verify the offered motor’s feedback cable, power cable, connector condition, shaft condition, and test documentation before purchase.
Why can a New Surplus servo motor cost less than an OEM factory unit?
New Surplus stock often comes from unused machine-builder inventory, cancelled automation projects, maintenance stores, or warehouse liquidation. It may be unused but no longer in factory packaging. Request actual nameplate photos, storage history, shaft and connector photos, insulation-test evidence, encoder test information, brake test results if fitted, packaging photos, and warranty terms.
What testing should a supplier perform before shipment?
For a KEB A3.SM.000-62DY servo motor, request testing tied to the exact motor:
- Verify the complete A3.SM.000-62DY nameplate, serial number, voltage, power, speed, feedback, and brake markings
- Photograph the shaft, keyway, flange, mounting pilot, power connector, feedback connector, cable exits, housing, and all labels
- Inspect for shaft runout, damaged keyway, bearing noise, corrosion, oil contamination, cracked connector shells, cut cables, and impact damage
- Measure phase-to-phase winding resistance and compare phase balance
- Perform insulation-resistance testing only on isolated motor power windings using the manufacturer-approved procedure
- Check protective-earth continuity between the frame and protective-earth point
- Test feedback on a compatible KEB servo drive or encoder test fixture
- Run the motor at controlled speed with a compatible drive while monitoring current, temperature, vibration, encoder stability, and fault status
- Test holding-brake release and holding function if the exact motor includes a brake
- Provide a test report, actual-unit photos or video, ESD-safe connector protection, foam-supported packing, and written warranty terms
A seller should identify the unit plainly as New Original / New Surplus, Refurbished (tested), or Used Removed From Working Equipment. “Turns freely” is not a servo-motor functional test.