
 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Core Product Summary (Brand / Model / Key Attributes)
The National Instruments PXI-7344 is a 4-axis high-performance motion controller engineered for precision stepper and servo motor automation tasks. Designed for integration into PXI and CompactPCI chassis architectures, it delivers multi-axis coordinated motion, trajectory generation, and closed-loop position control for industrial manufacturing, robotics, and automated test equipment (ATE).
The module utilizes an onboard digital signal processor (DSP) to handle complex motion algorithms independently from the host controller, ensuring deterministic trajectory execution. It supports stepper or servo drives across 4 independent axes, providing PID feedback loops, electronic gearing, contouring, linear and circular interpolation, and dedicated hardware interlocks. Integrated directly into the PXI backplane, the PXI-7344 coordinates seamlessly with data acquisition and instrumentation modules within a unified test environment.
Key Technical Specifications
| Parameter | Verified Specification Value |
| Manufacturer | National Instruments (NI) |
| Model / Part Number | PXI-7344 |
| Product Type | 4-Axis PXI Motion Controller Module |
| Form Factor | 3U PXI / CompactPCI slot module |
| Controlled Axes | 4 independent axes (stepper or servo support) |
| Control Loops | PID with velocity and acceleration feedforward (servo mode) |
| Trajectory Generation | Trapezoidal and S-curve velocity profiles |
| Interpolation Modes | Linear, circular, helical, and spherical interpolation across multiple axes |
| Feedback Inputs | Quadrature encoder inputs per axis (up to max frequency limits) |
| Bus Interface | PXI backplane (PCI-based data transfer) |
| Software Environment | NI-Motion driver software, LabVIEW, LabWindows/CVI, C/C++ |
Detailed Product Overview
The National Instruments PXI-7344 functions as a core processing and command node for multi-axis mechanical systems. By executing onboard motion planning algorithms via its dedicated DSP, the module unloads trajectory calculations from the host CPU, enabling smooth acceleration, deceleration, and velocity profiling without software jitter.
The controller accommodates both stepper and DC/ブラシレス servo drives through configurable command outputs (such as step/direction pulses or \pm 10 V analog control signals). It reads encoder feedback signals directly, closing the loop for precise position and velocity regulation. Multi-axis coordination features like linear and circular interpolation allow complex contouring paths for automated dispensing, machining, and material handling. Integration with NI-Motion drivers and LabVIEW software enables rapid system configuration, tuning, and synchronized test sequencing.
Dimensions, Mounting & Connection Notes
The PXI-7344 is built in a standard 3U-height PXI module enclosure. It slides directly into an available peripheral slot of a PXI chassis and secures via top and bottom panel screws to ensure robust chassis ground continuity.
All external control signals, encoder feedback lines, and drive interfaces route through a high-density front-panel SCSI-type connector. Due to the sensitivity of encoder and analog feedback circuits, proper shielded cabling and a dedicated motion breakout accessory (such as the NI UMI series) must be utilized to prevent electrical noise interference in industrial environments.
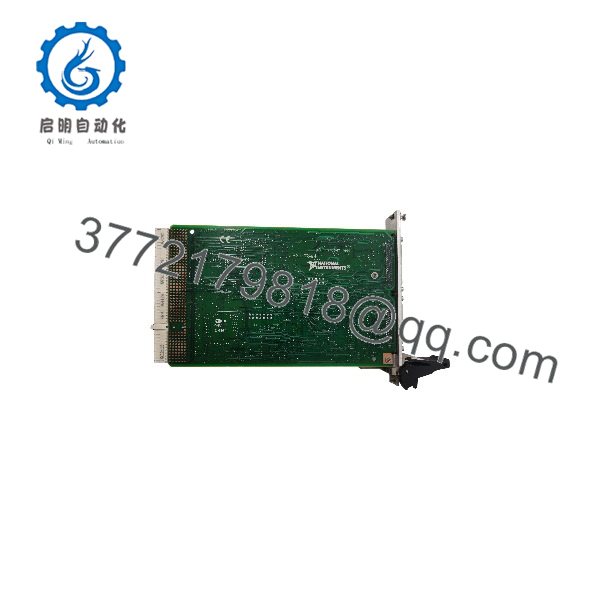
PXI-7344
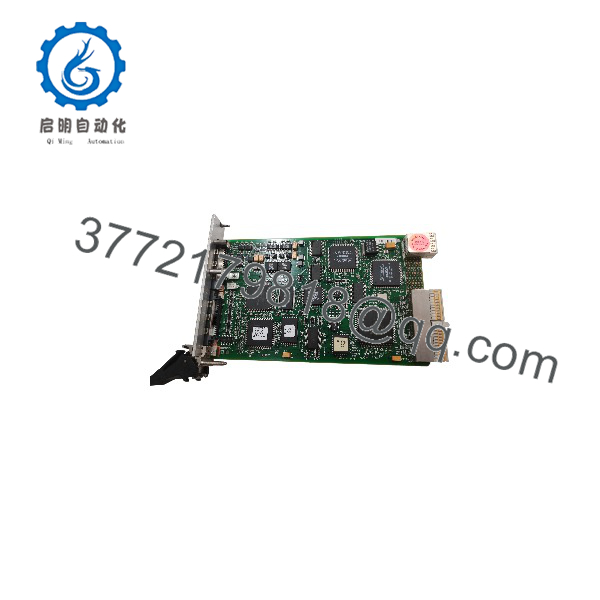
PXI-7344
Engineering Selection Highlights
- 4-Axis Coordinated Control: Manages up to four independent motor axes with advanced linear, circular, and contouring interpolation capabilities.
- Onboard DSP Processing: Executes demanding trajectory equations and PID control loops locally, freeing host system resources.
- Stepper & Servo Compatibility: Adapts to diverse actuator types through selectable step/direction or analog command outputs.
- Hardware-Timed Integration: Synchronizes motion profiles with external data acquisition (DAQ) and instrumentation triggers via the PXI backplane and RTSI bus.
- Comprehensive Fault Protection: Includes dedicated inputs for limit switches, emergency stops (E-stop), and following-error monitoring.
System Compatibility & Integration Requirements
| Item / Dependency | Verified Compatibility or Requirement | Practical Note |
| Chassis Compatibility | PXI or PXI Express (Hybrid) chassis | Must be installed in a standard PXI peripheral slot with bus master capabilities. |
| Accessory Breakout | NI UMI-7764 or compatible motion interface accessories | Required to bridge the high-density front-panel connector to screw terminals and drive amplifiers. |
| Software Environment | NI-Motion driver software, LabVIEW, or C/C++ | Software toolkits must support motion configuration, axis calibration, and trajectory generation. |
| Cabling | Shielded motion control cable (e.g., SH68-68-EP) | Connects the PXI-7344 front panel directly to external terminal blocks or amplifier drives. |
FAQ
What is the primary function of the NI PXI-7344?
The PXI-7344 is a 4-axis motion controller designed to provide precision trajectory generation, position feedback loops, and coordinated motor control in automated systems.
Does the PXI-7344 support both stepper and servo motors?
Yes, the module can be configured to command either stepper motor drives (via step/direction pulses) or servo drives (via analog control signals).
How does the module handle trajectory calculations?
Trajectory generation and PID control loops are processed locally by an onboard digital signal processor (DSP), ensuring deterministic motion independent of the host PC operating system.
Can multiple axes be interpolated together?
Yes, the controller supports multi-axis linear, circular, and contouring interpolation for complex motion paths.
What hardware is required to connect motors and encoders to the module?
The module typically interfaces through a shielded cable to an external motion accessory block (such as the NI UMI-7764) which breaks out signals to standard screw terminals.
Verification & Troubleshooting Notes
- Following Error Faults: If a servo axis faults out with a following error, verify that encoder feedback wiring is correct, encoder lines are shielded, and PID loop gains are properly tuned.
- Limit Switch Interlocks: If motion commands fail to execute, inspect the hardware limit switch and emergency stop inputs on the breakout block to ensure safety interlocks are closed and not active.
- Drive Command Scaling: Ensure that output signal scaling matches the input sensitivity requirements of the connected motor amplifier (e.g., matching \pm 10 V spans for servo drives).



