
 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Core Product Summary
The Yaskawa UGRMEM-01SNQ12 is a compact, high-precision DC servo motor from Yaskawa’s legacy Minertia R-Series family. Designed for low-inertia, high-response positioning and speed control applications, this motor features a slotless/coreless armature construction using high-coercivity rare-earth permanent magnets. It delivers smooth, cogging-free rotation across both high-speed runs and micro-stepping low-speed operations.
Equipped with an integrated optical encoder for real-time position and speed feedback, the UGRMEM-01SNQ12 is engineered for automated assembly equipment, semiconductor processing systems, IC bonders, labeling machinery, and robotic actuators. Its totally enclosed, self-cooled frame protects internal components against industrial dust and minor contaminants in continuous-duty automation environments.
Key Technical Specifications
| Parameter | Specification |
| Manufacturer | Yaskawa Electric Corporation |
| Model / Part Number | UGRMEM-01SNQ12 |
| Motor Series | Minertia R Series (UGRMEM Frame 01) |
| Motor Type | Coreless / Low-Inertia DC Servo Motor |
| Magnet Type | High-energy rare-earth permanent magnet |
| Enclosure Rating | Totally enclosed, self-cooled (IP/Industrial standard) |
| Feedback Device | Integrated optical incremental encoder |
| Insulation Class | Class B rating |
| Duty Rating | Continuous operation |
| Operating Ambient Temperature | -10°C to +40°C (non-condensing) |
Detailed Product Overview
The Yaskawa UGRMEM-01SNQ12 belongs to the Minertia R-Series motor lineup, developed to meet the demanding torque-to-volume and torque-to-weight requirements of robotic arms and precision X-Y positioning tables. By using a slotless armature design backed by rare-earth permanent magnets, the motor eliminates magnetic cogging, providing uniform torque generation throughout every rotation.
Dynamic Motion & Feedback Integration
The low rotor inertia of the UGRMEM-01SNQ12 enables fast acceleration and rapid reversal cycles without placing excess thermal stress on the motor winding. The factory-mounted optical encoder routes directly to host servo drives (such as Yaskawa SERVOPACK series amplifiers), allowing closed-loop speed regulation and position feedback.
Mechanical & Environmental Construction
Built into a compact round frame, the UGRMEM-01SNQ12 uses precision bearings designed to eliminate axial shaft play (thrust movement), extending bearing operational life in high-cycle picking and insertion machinery. The totally enclosed housing prevents industrial airborne particulates from interfering with internal brush or optical encoder components.
Engineering Selection Highlights
- Coreless Low-Inertia Armature: Provides fast dynamic acceleration and low electrical/mechanical time constants for high-cycle start-stop positioning.
- Cogging-Free Motion: Slotless structure ensures smooth low-speed rotation, making it suitable for delicate semiconductor and optical inspection equipment.
- Integrated Optical Encoder: Features a factory-aligned encoder on the rear shaft extension for feedback integration with servo amplifiers.
- High Torque-to-Size Ratio: Rare-earth magnets deliver strong continuous and peak torque from a compact motor footprint.
- Zero Shaft Endplay Bearing Assembly: Precision bearing configuration prevents axial shaft drift during rapid directional shifts.
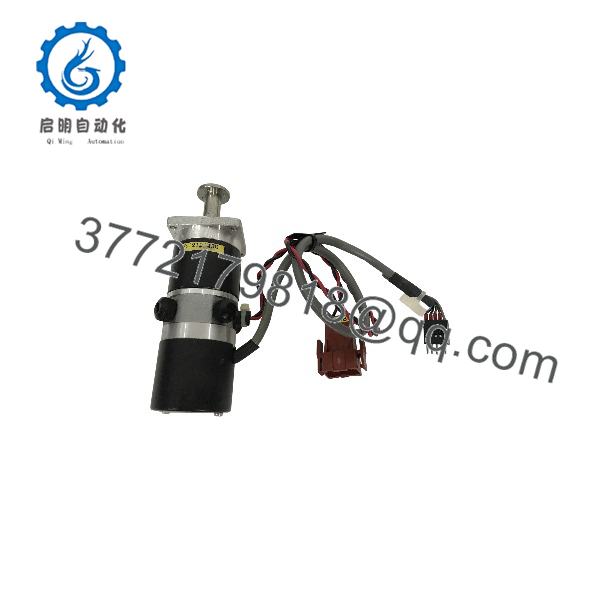
UGRMEM-01SNQ12
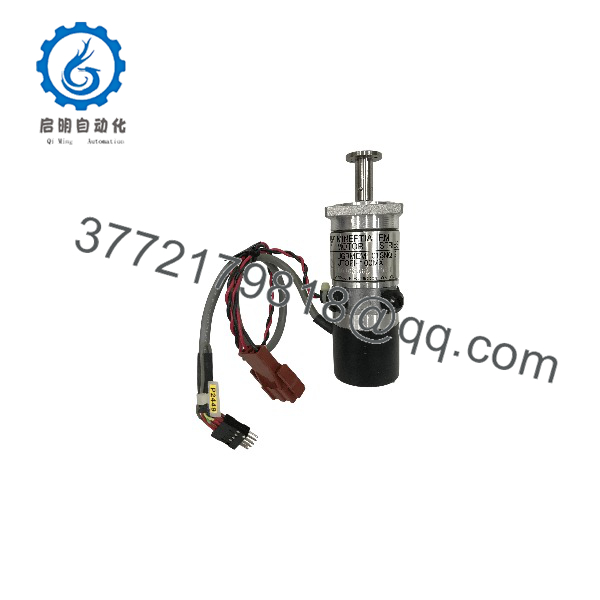
UGRMEM-01SNQ12
System Compatibility & Integration Requirements
| Item / Dependency | Verified Compatibility or Requirement | Practical Note |
| Servo Amplifier / Drive | Yaskawa DC SERVOPACK Series (e.g., CPCR-PF / CPCR-FR series) | Ensure the drive is configured for coreless DC servo motors and correct feedback pulse counts. |
| Power Distribution | Regulated DC servo drive armature output | Never connect the motor armature directly to AC utility lines. |
| Feedback Cabling | Shielded encoder feedback cable assembly | Route encoder signals separately from armature power leads to prevent electrical noise coupling. |
| Mechanical Mounting | Standard front-flange mounting face | Ensure precise axial alignment with connected gearheads or lead screws to prevent bearing side-loading. |
Dimensions, Mounting & Connection Notes
- Mounting Orientation: Can be mounted in any orientation (horizontal, vertical, or angled). Fasten securely via the front mounting flange.
- Coupling Considerations: Use flexible, high-torsional-stiffness couplings when connecting the motor shaft to a lead screw or gearbox to compensate for slight shaft misalignment.
- Power Connection: Connect armature leads to the corresponding armature output terminals on the DC servo drive. Verify correct polarity to ensure intended direction of rotation.
- Encoder Cabling: Ensure the optical encoder connector is latched before applying power. Ground cable shielding at the amplifier end to prevent pulse loss in high-EMC environments.
FAQ
What type of motor is the Yaskawa UGRMEM-01SNQ12?
It is a low-inertia, coreless DC servo motor equipped with an integrated optical encoder, belonging to Yaskawa’s Minertia R-Series family.
What are the main advantages of a coreless DC servo motor?
Coreless DC motors offer low rotor inertia, high acceleration rates, smooth low-speed rotation without cogging torque, and high power density in a small frame size.
Which amplifiers are compatible with the UGRMEM-01SNQ12?
It is designed to operate with Yaskawa DC SERVOPACK amplifiers (such as the CPCR series) or equivalent third-party DC servo drives supporting brush-type DC servo motors with optical encoder feedback.
What applications typically use the UGRMEM-01SNQ12?
It is widely used in high-precision automated assembly equipment, IC bonders, semiconductor handling systems, small robotic actuators, and X-Y positioning tables.
Verification & Troubleshooting Notes
- Motor Does Not Rotate / No Torque: Measure DC voltage across the motor armature leads while sending a motion command from the drive. If voltage is present but the shaft does not turn, check internal motor brushes for wear or mechanical binding in the driven load.
- Position Error / Servo Runaway: Check encoder cable continuity and shield grounding. Verify that encoder A/B phase channels are wired correctly to the servo drive; reversed encoder phases can cause immediate overspeed/runaway faults.
- Overheating During Operation: Inspect the motor for mechanical overload or excessive side-load on the shaft. Ensure the duty cycle and peak current limits set in the servo drive match the motor’s thermal capabilities.
- Unusual Shaft Noise or Vibration: Inspect flexible couplings for misalignment. Check the motor mounting bolts and verify that shaft bearings show no axial or radial play.



