WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
3. Key Technical Specifications
| Parameter | Value |
|---|---|
| Continuous Torque (standstill 60 K) | 2.7 Nm |
| Continuous Current (standstill 60 K) | 3.1 A |
| Continuous Torque (standstill 100 K) | 3.1 Nm |
| Maximum Torque | 8.1 Nm |
| Maximum Current | 12.4 A |
| Maximum Speed | 7,500 rpm |
| Torque Constant (20 °C) | 0.95 Nm/A |
| Voltage Constant (20 °C) | 58.2 V/1,000 min⁻¹ |
| Winding Resistance (20 °C) | 3.9 Ω |
| Winding Inductivity | 21.3 mH |
| Number of Pole Pairs | 4 |
| Rotor Moment of Inertia (without brake) | 0.00014 kg·m² |
| Holding Brake Torque | 4 Nm (electrically released) |
| Encoder | Optical multiturn absolute, Hiperface, 128 signal periods |
| Cooling | Natural convection (NN) |
| Shaft | Plain shaft with shaft sealing ring |
| Protection Class | IP65 |
| Weight (with brake) | approx. 3.9 kg |
| Ambient Temperature | 0 °C to +40 °C |
4. Product Introduction & Supply Chain Strategy
The Bosch Rexroth MSK040C-0600-NN-M1-UG1-NNNN is a compact IndraDyn S synchronous servomotor designed for high-dynamics positioning axes. It combines natural convection cooling, a plain shaft, a multiturn absolute Hiperface encoder, and an electrically released 4 Nm holding brake in a size 040 frame.
Purchasing this unit as New Surplus protects against lead-time variability and potential last-time-buy constraints on the MSK platform. Genuine new motors deliver the full expected service life and OEM-level reliability, avoiding the elevated failure risk and shorter residual life typical of refurbished units. For plants running multiple MSK axes, holding one or two units as buffer stock reduces total cost of ownership by eliminating unplanned downtime.
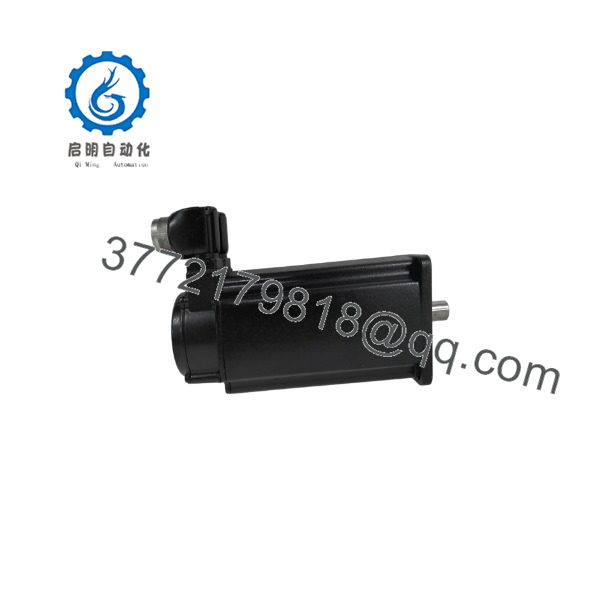
MSK040C-0600-NN-M1-UG1-NNNN
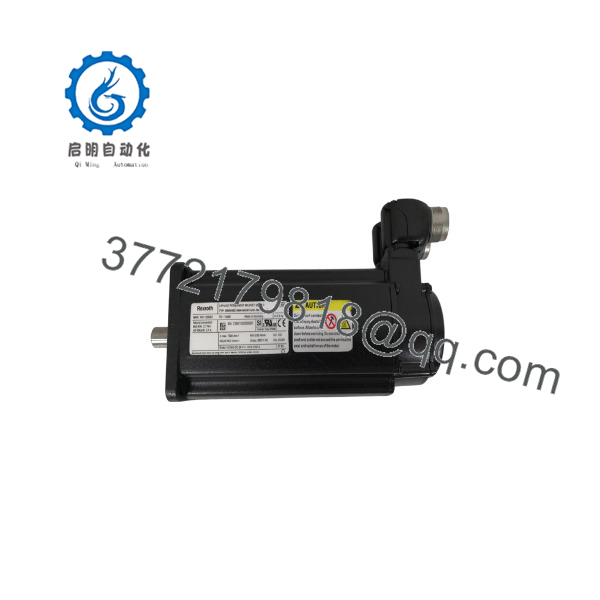
MSK040C-0600-NN-M1-UG1-NNNN
5. Installation & Configuration Guide
Stage 1: Pre-Installation (Prep & Safety)
Lock out and tag out the drive and machine power. Wear a grounded ESD wrist strap. Record the existing motor’s exact type code, encoder settings, and mechanical alignment marks. Photograph cable routing and connector orientation. Verify the drive is parameterized for the MSK040C-0600 winding and M1 encoder.
Stage 2: Removal
Disconnect power and feedback connectors. Support the motor weight, loosen the mounting flange bolts evenly, and withdraw the motor straight off the coupling or gearbox to avoid shaft or seal damage.
Stage 3: Installation (Clone & Seat)
Inspect the plain shaft and sealing ring. Align the new motor to the existing mounting marks and coupling. Seat the motor fully against the flange and tighten bolts to the specified torque in a cross pattern. Route cables so the rotatable connectors (240°) sit in the same orientation as the original.
Stage 4: Power-On & Testing
Reconnect power and encoder cables. Release the holding brake (24 V). Perform a low-speed jog to confirm direction and encoder feedback. Check for abnormal noise or vibration, then run the axis through its normal motion profile while monitoring drive diagnostics for temperature, current, and position error.
6. Firmware/Software Versions & Upgrade Notes
The MSK040C-0600-NN-M1-UG1-NNNN uses a fixed optical multiturn absolute Hiperface encoder (128 signal periods). No motor firmware is user-upgradable. Drive-side firmware and parameter sets must match the motor’s winding code (0600) and encoder type (M1).
Always store the original drive parameter file before replacement. Loading parameters intended for a different winding or single-turn encoder will cause following-error faults or incorrect torque scaling. Do not attempt to operate the motor with an incompatible encoder interface or altered pole-pair settings. Confirm the holding-brake control logic in the drive matches the electrically released 4 Nm brake.
7. Frequently Asked Questions (FAQ)
Is this motor new or refurbished?
This is Brand New Surplus / Original New. It has never been installed in a machine, carries no operating hours, and is not a repaired or rebuilt unit.
Why does the price sit between current OEM list and used-market offers?
New Surplus pricing reflects the cost of securing genuine unused inventory. It remains substantially lower than full OEM list while avoiding the reliability and warranty limitations of used or refurbished motors.
Does this motor include a holding brake?
Yes. The “UG1” designation specifies a plain shaft and an electrically released holding brake rated 4 Nm.
Can I hot-swap this servo motor?
No. Always de-energize the drive and apply lock-out/tag-out before removing or installing the motor. Residual voltage and uncontrolled brake release present safety and equipment risks.
Will the multiturn absolute position be retained after power loss?
Yes. The optical multiturn absolute Hiperface encoder retains absolute position across power cycles within its designed multiturn range.
What is the expected service life of a new unit versus a refurbished one?
A new motor typically delivers 10–15 years of service under normal industrial conditions when properly applied. Refurbished units often show reduced remaining life due to prior thermal and mechanical stress.
What warranty applies?
New Surplus units are covered by a standard 1 year warranty against defects in materials and workmanship under normal operating conditions.