 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | Kollmorgen |
| Full Model | AKM22E-ANB2R-00 |
| Product Family | AKM synchronous servo motors |
| Motor Type | Brushless permanent-magnet AC servo motor |
| Frame Size | 58 mm |
| Rotor Length | 2 |
| Winding Code | E |
| Maximum Speed | 8,000 RPM |
| Published Power Reference | 0.58 kW |
| Supply / Drive Reference | 320 V DC class application reference |
| Feedback Type | Two-pole single-turn resolver |
| Feedback Construction | Inductive resolver feedback |
| Resolver Size Code | 10 / 15 / 21 |
| Holding Brake | 24 V DC fail-safe holding brake |
| Shaft Type | Smooth shaft |
| Mounting Flange | IEC flange |
| Flange Accuracy Class | N |
| Connector Arrangement | Two SpeedTec-ready connectors |
| Connection Arrangement | Separate motor-power and feedback connection points |
| Motor Temperature Protection | Electrically isolated thermistor in motor winding |
| Ambient Operating Temperature | 5 to +40 °C |
| Humidity Limit | Up to 95% RH, non-condensing |
| Environmental Protection | Verify exact nameplate rating; market references identify an IP54 version |
| Mounting Orientation | Horizontal or vertical, subject to load and mechanical design review |
| Bearing Type | Grease-lubricated ball bearings |
| Typical Applications | Packaging equipment, machine tools, robotics, indexing systems, conveyors, and compact positioning axes |
| Lifecycle Note | Confirm full motor code, brake type, resolver type, shaft dimensions, flange, connector orientation, and winding before ordering |
The AKM22E-ANB2R-00 is a Kollmorgen AKM brushless synchronous servo motor with a 58 mm frame, smooth shaft, single-turn resolver feedback, two SpeedTec-ready connectors, and a 24 V DC holding brake. Market references identify the model as an 8,000 RPM, 0.58 kW, 320 V DC-class motor.
Product Introduction
The Kollmorgen AKM22E-ANB2R-00 is a compact permanent-magnet servo motor for closed-loop motion axes that require fast response, stable low-speed control, and repeatable position control. It is commonly used with compatible Kollmorgen servo amplifiers in packaging machines, machine tools, indexing mechanisms, conveyors, and compact robotic equipment. The 58 mm frame and smooth shaft support space-constrained axes using clamp couplings or matched gearboxes.
This motor includes a 24 V DC holding brake and resolver feedback. The brake is intended to hold a stopped axis when drive power is removed; it is not a service brake for stopping a moving load. Before replacing the motor, match the complete code, winding, resolver, brake, connector arrangement, shaft style, flange dimensions, gearbox coupling, and servo-drive motor file. A physically similar AKM motor can still be electrically incompatible.
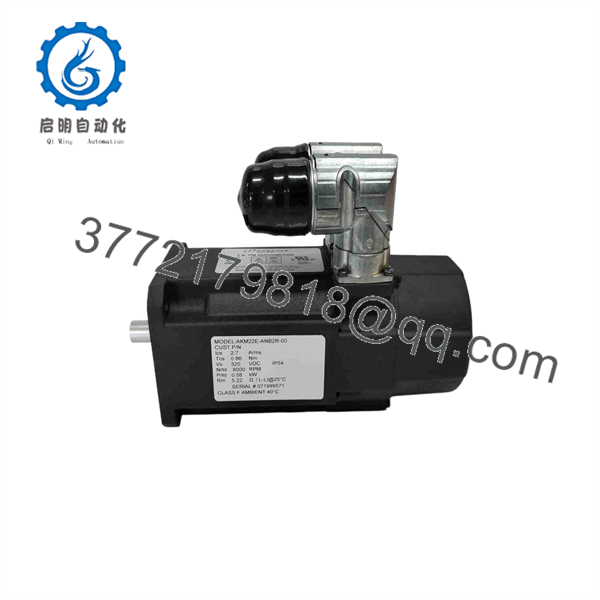
AKM22E-ANB2R-00
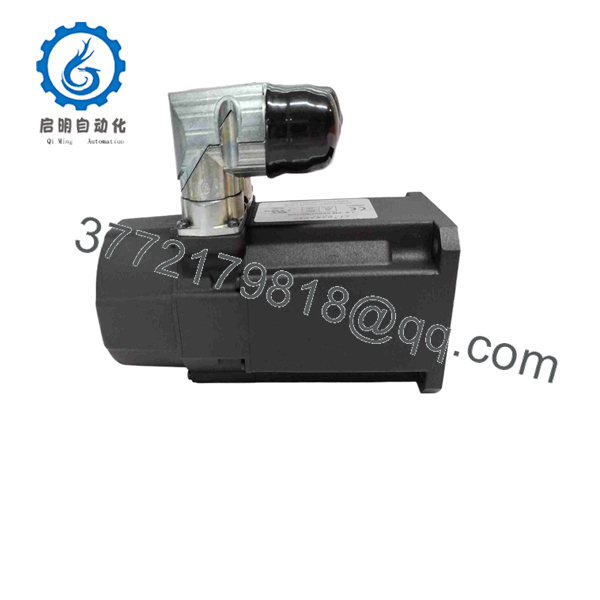
AKM22E-ANB2R-00
Troubleshooting Quick Reference
| Symptom | Possible Cause | Relevance to this Part | Quick Check Method | Recommendation |
|---|---|---|---|---|
| Motor does not rotate when servo drive enables | Brake remains engaged, drive not enabled, STO active, motor phases open, faulted amplifier | ⚠️ Medium | Confirm the drive enable state, check STO circuit, and measure 24 V DC at the brake coil during the enabled command | Check brake release and drive status before replacing the motor |
| Motor hums or locks but will not turn | Incorrect phase sequence, seized mechanics, engaged brake, wrong motor parameters | ⚠️ Medium | Disconnect the load only under an approved procedure; verify free shaft rotation with power removed; review motor file and phase wiring | Inspect mechanics and configuration first. Do not swap phase wires randomly |
| Axis drops or drifts when power is removed | Brake coil failure, brake wiring fault, worn brake, excessive vertical load, mechanical back-drive | ✅ High | Measure brake-coil voltage and resistance against the approved motor data; inspect the mechanical load and gearbox holding capacity | The 24 V brake is a holding brake. Secure vertical loads before testing and replace the motor or brake assembly if holding torque is inadequate |
| Motor runs but position error increases | Resolver cable fault, resolver connector loose, feedback configuration mismatch, coupling slip | ⚠️ Medium | Inspect feedback connector; check resolver diagnostics in the drive; mark shaft-to-coupling position and inspect for slip | Verify feedback and mechanical coupling before replacing the motor |
| Drive reports resolver or feedback fault | Broken resolver cable, damaged connector pins, incorrect resolver selection, internal resolver failure | ⚠️ Medium | Check cable continuity and shielding; reseat connectors; compare drive feedback configuration to the exact motor code | Test with a known-good compatible feedback cable before condemning the motor |
| Motor overheats under normal load | Overload, poor tuning, blocked cooling, high ambient temperature, bearing wear, brake partially energized | ⚠️ Medium | Measure motor surface temperature, phase current, and duty cycle; check that brake voltage fully releases the brake | Reduce load or improve tuning/cooling first. Investigate the brake if the motor heats while stationary |
| Motor is noisy or vibrates during operation | Misaligned coupling, damaged bearing, loose mounting bolts, resonance, incorrect servo tuning | ⚠️ Medium | Check coupling alignment, flange bolts, gearbox condition, and vibration trend; run at low speed without load if safe | Correct mechanical alignment and tuning before replacing the motor |
| High following error during acceleration only | Acceleration too high, torque limit too low, load inertia mismatch, belt/pulley slip, loose coupling | ❌ Low | Trend commanded torque, actual position, and velocity during acceleration; inspect mechanical transmission | Adjust acceleration and verify load mechanics. The motor may be healthy |
| Motor reaches commanded position but oscillates | Servo gain too high, resonance, loose coupling, encoder/resolver shielding issue | ❌ Low | Review tuning parameters and inspect coupling rigidity; check feedback cable shield termination | Tune the drive and correct mechanical resonance before replacing the motor |
| Brake releases slowly or chatters | Weak 24 V supply, voltage drop in long cable, wrong brake supply, failing brake coil | ⚠️ Medium | Measure brake voltage at the motor connector during enable and compare with supply at source | Use a properly sized 24 V DC brake supply and inspect cable resistance |
| Replacement motor will not commission | Wrong winding code, incorrect resolver type, brake mismatch, incompatible motor database | ✅ High | Compare full nameplate code, drive motor selection, feedback settings, brake voltage, and power/feedback connectors | Do not use a generic AKM file. Load the configuration for the exact motor variant |
| Replacement motor does not mate with existing cables | Connector orientation or connector family mismatch | ✅ High | Compare the old motor’s connector arrangement and cable plug type to the replacement before installation | Match the complete motor suffix and connector layout. Two SpeedTec-ready connectors do not guarantee every cable assembly fits |
| Motor has intermittent feedback faults after washdown | Moisture ingress, damaged connector seals, cable-jacket damage, corrosion | ⚠️ Medium | Inspect connector O-rings, contact pins, cable strain relief, and housing seals; check for condensation | Dry and repair the connection system before energizing. Replace compromised cables or motor assemblies |
| Motor shaft or coupling is damaged | Overhung load, coupling misalignment, impact during removal, incorrect puller use | ✅ High | Inspect shaft runout, keyway/smooth-shaft surface, coupling bore, and bearing noise | Do not hammer the shaft. Replace or repair damaged mechanical components before reassembly |
❗ Brake warning: The integrated 24 V DC brake holds the motor shaft after power removal. It is not designed to repeatedly stop a moving axis. For vertical or suspended loads, use a controlled deceleration sequence plus a mechanical safety strategy. Never rely on the brake alone while personnel are in a hazard zone.
❗ Feedback warning: This motor uses resolver feedback, not a standard incremental encoder. The servo drive must be configured for the correct resolver type and motor winding. A wrong motor database can create commutation faults, unstable torque, or immediate drive trips.
❗ Shaft warning: This model has a smooth shaft. Use the specified clamp coupling or approved hub arrangement. Do not use set screws directly on the shaft unless the mechanical design explicitly permits it; point loading can damage the shaft surface and create runout.
❗ Mains warning: Never connect the motor directly to AC mains. It must be driven by a compatible servo amplifier with the correct current limits, feedback configuration, brake control, and motor protection settings.
If troubleshooting remains unresolved, provide technical support with photos of the full motor nameplate, motor and feedback connectors, servo-drive fault history, cable labels, brake supply voltage, resolver configuration, coupling, gearbox, and a short vibration or noise video if safe to capture.
Frequently Asked Questions
What does the Kollmorgen AKM22E-ANB2R-00 do?
The AKM22E-ANB2R-00 is a brushless permanent-magnet servo motor used with a compatible servo drive for precise rotary motion. It provides controlled speed, torque, and position feedback for machine axes such as indexing tables, packaging mechanisms, conveyors, and compact robotic joints.
Does this motor have a holding brake?
Yes. This model includes a 24 V DC holding brake. Its job is to hold the shaft when power is removed, particularly where gravity or back-driving loads could move the axis. It is not intended to be used as a dynamic braking device during normal motion.
What type of feedback does it use?
It uses a single-turn inductive resolver with a two-pole design. The resolver provides rotor-position feedback to the compatible servo amplifier for commutation and closed-loop motion control. Verify the drive’s resolver settings and motor file before commissioning.
What is the maximum speed?
The published maximum speed is 8,000 RPM. Maximum usable machine speed can be lower because it depends on the servo-drive voltage, mechanical load, gearbox ratio, coupling rating, rotor inertia, duty cycle, and application safety limits.
What does the E winding code mean?
The E identifies the motor’s winding variant. Winding selection affects the motor’s voltage, speed, torque, and compatible drive setup. Do not substitute a different AKM22 winding just because its frame, shaft, or brake looks the same. Match the complete nameplate and use the correct drive motor file.
Can I hot-swap this servo motor?
No. Shut down the servo system, isolate electrical energy, secure any moving or suspended load, wait for DC bus discharge, remove the brake supply as required, and use lockout/tagout before disconnecting motor or feedback cables. Disconnecting a servo motor under power can damage the drive, feedback electronics, connectors, or brake circuit.
Why does the drive show a resolver fault after replacing the motor?
Most cases involve a wrong or damaged feedback cable, loose connector, incorrect resolver selection, wrong motor configuration file, broken shielding, or an incompatible motor revision. Confirm the full motor code, cable pinout, resolver type, and drive feedback settings before assuming the replacement motor is defective.
Why does the vertical axis fall or drift after power loss?
The brake may not be receiving or releasing the correct 24 V DC signal during normal operation, may be worn, or may not have enough holding torque for the actual load. Check brake wiring, measured brake voltage, mechanical load, gearbox back-drive characteristics, and the machine’s counterbalance system. Secure the load before diagnosis.
Is AKM22E-ANB2R-00 obsolete?
It belongs to the established Kollmorgen AKM servo-motor family, and availability can vary by exact winding, feedback, brake, connectors, and lifecycle revision. For a critical machine, keep an exact matched spare, the servo-drive motor database, parameter backup, cable part numbers, brake-circuit drawings, and coupling/gearbox data.
What condition should I request for a production-critical spare?
Request New Original / New Surplus with full nameplate, shaft, flange, brake, connector, and packaging photos. For a Refurbished (tested) motor, request documented tests for insulation resistance, winding resistance balance, resolver feedback, brake function at 24 V DC, shaft runout, bearing noise, connector condition, and a no-load run on a compatible drive. Ask for test evidence, actual stock confirmation, warranty, return terms, and lead time before purchase.