 WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | Kollmorgen |
| Alternate Identification | CB06560 |
| Full Model Number | PRD-B040SAIB-62 |
| Product Series | SERVOSTAR CD |
| Product Type | Single-axis digital servo drive |
| Control Application | Closed-loop control of compatible servo motors |
| Continuous Current | 6 A, as identified in distributor product data |
| Feedback Type | Resolver |
| Current-Loop Update Rate | 62.5 µs |
| Velocity-Loop Update Rate | 250 µs |
| Resolver Transformation Ratio | 0.47 |
| Resolver Excitation Frequency | 7–8 kHz |
| Resolver Excitation Voltage | 4.25 VAC from drive |
| Resolver Maximum Stator DC Resistance | 120 Ω |
| Resolver Excitation Current | 55 mA AC RMS maximum |
| Resolver Signal Voltage to Drive | 2 VAC |
| Dimensions | 249 mm × 163 mm × 83.3 mm |
| Installation Requirement | Separate power and motor-feedback cables by at least 20 cm; use correctly terminated shielding |
| Lifecycle Status | Legacy / obsolete drive series; availability depends on surplus inventory |
| Exact Compatibility Check | Confirm motor model, resolver data, supply configuration, parameter set, and drive revision before installation |
The PRD-B040SAIB-62 is identified as a Kollmorgen SERVOSTAR CD servo drive with resolver feedback, 6 A continuous-current capability, a 62.5 µs current loop, and a 250 µs velocity loop. Public distributor information also specifies the resolver electrical requirements and the cited mechanical dimensions. Verify mains-input rating, motor compatibility, connector pinout, firmware, brake-output details, and parameter-file compatibility against the drive nameplate and applicable Kollmorgen documentation before energizing the unit.
Product Introduction
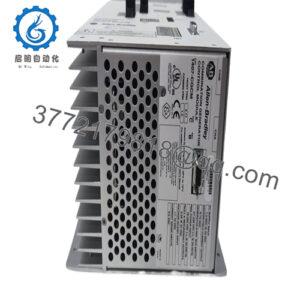
The Kollmorgen CB06560 PRD-B040SAIB-62 is a SERVOSTAR CD single-axis digital servo drive for closed-loop motion control of compatible industrial servo motors. It uses resolver feedback to regulate motor position and velocity in machinery such as converting equipment, packaging machines, material-handling systems, and formed-metal production equipment.
This drive is selected when a failed SERVOSTAR CD axis needs an exact legacy replacement without changing the motor, motion controller, cables, or machine program. Its 6 A continuous-current rating and resolver interface are key match points. Verify the original drive label, motor nameplate, resolver wiring, control interface, and saved parameter set before replacement.
Troubleshooting Quick Reference
| Symptom | Possible Cause | Relevance to This Part | Quick Check Method | Recommendation |
|---|---|---|---|---|
| No display, no LEDs, or no drive response | Missing control power, blown fuse, open disconnect, failed cabinet supply | ❌ Low | Measure the specified input supply at the drive input terminals with a properly rated meter; check upstream fuses, contactors, and disconnect status | Repair the incoming-power issue before replacing the CB06560 |
| Drive powers up but enters a fault state immediately | Incorrect motor parameters, resolver fault, encoder cable damage, internal drive fault | ⚠️ Medium to high | Record the complete fault code; inspect feedback connector seating; compare drive parameters with the motor nameplate and backup file | Resolve feedback and parameter issues first; replace only if the fault follows the drive |
| Motor does not enable | Missing enable signal, active E-stop circuit, safety relay open, drive inhibit, controller not issuing command | ❌ Low | Check the enable input and safety-chain status from the electrical schematic; verify the motion controller is commanding enable | Trace the safety and enable circuit before condemning the servo drive |
| Motor hums or vibrates but will not rotate | Resolver wiring error, phase wiring error, incorrect commutation setup, mechanical jam | ⚠️ Medium | With power isolated, inspect motor power and resolver cable pinout; rotate the load manually if safe; compare configuration with the removed drive | Verify motor phases and resolver wiring; do not continue trial-and-error tuning |
| Axis runs away, overshoots, or oscillates | Wrong gain values, incorrect motor file, reversed feedback polarity, mechanical compliance | ⚠️ Medium | Load the original parameter backup; compare velocity and position feedback direction in commissioning software | Restore known-good parameters before changing hardware |
| Overcurrent or short-circuit fault | Shorted motor winding, damaged motor cable, failed brake coil, failed output stage | ⚠️ Medium | Isolate power, disconnect the motor cable, measure phase-to-phase resistance and phase-to-ground insulation; inspect cable damage | Test motor and cable before installing another drive; a shorted motor can damage the replacement |
| Overtemperature fault | Blocked airflow, high panel temperature, overloaded axis, failed cooling path | ❌ Low to medium | Measure enclosure temperature and inspect ventilation; compare commanded load and duty cycle with the original application | Correct cooling or mechanical-load issues before replacing the drive |
| Communication fault with controller | Wrong command-interface configuration, broken cable, controller fault, parameter mismatch | ❌ Low to medium | Check controller diagnostics, cable continuity, connector pins, and interface settings against the original configuration | Verify external control signals and configuration before replacing the servo drive |
| Fault appears only after drive replacement | Firmware mismatch, wrong parameter file, incorrect DIP/jumper setting, incompatible motor configuration | ✅ High | Compare original and replacement labels, revision markings, connector layout, motor parameters, and stored configuration | Stop commissioning until settings match; request the correct revision if required |
| Drive functions briefly, then trips under motion load | Weak mains supply, deceleration energy issue, excessive mechanical load, failing motor cable | ⚠️ Medium | Monitor input voltage during acceleration; inspect load for binding; review the drive’s fault history and deceleration settings | Correct supply and mechanical problems before treating the drive as defective |
❗ Firmware and parameter-file mismatch: Back up the original drive before it fails, if possible. A replacement may power up normally but refuse to enable or create a tuning fault because its stored motor data differs. I have seen an otherwise correct replacement keep a machine down for two days because the site loaded a parameter set from a similar axis, not the exact axis.
❗ Resolver wiring and motor phasing: Do not guess. The PRD-B040SAIB-62 uses resolver feedback, and the resolver requirements matter. Record connector pinouts, shielding, excitation wiring, and phase connections before pulling the original drive. A phase or feedback mismatch can cause vibration, runaway motion, or an immediate fault.
❗ Cable separation: Keep motor power conductors and resolver-feedback wiring physically separated. Available product information specifically calls for at least 20 cm separation and proper shielding. Routing feedback beside high-current motor cables is a common cause of unstable position feedback and intermittent faults.
❗ Power and regeneration: Check incoming supply quality and the axis deceleration profile. A drive fault during hard stops may be caused by insufficient regeneration handling, a weak DC bus, or aggressive deceleration—not a failed servo drive.
❗ ESD and discharge time: Lock out incoming power, wait for the DC bus to discharge, confirm safe voltage with appropriate test equipment, and use a grounded wrist strap. I once watched someone swap a drive too early after shutdown; the DC bus still had energy and damaged the replacement during installation. Respect the discharge interval.
If diagnosis stalls, send technical support photos of the full drive label, revision code, motor label, fault display, connector wiring, resolver cable, parameter backup, and controller diagnostic log. Keep these checks in mind and you will save yourself 90% of typical rework time.
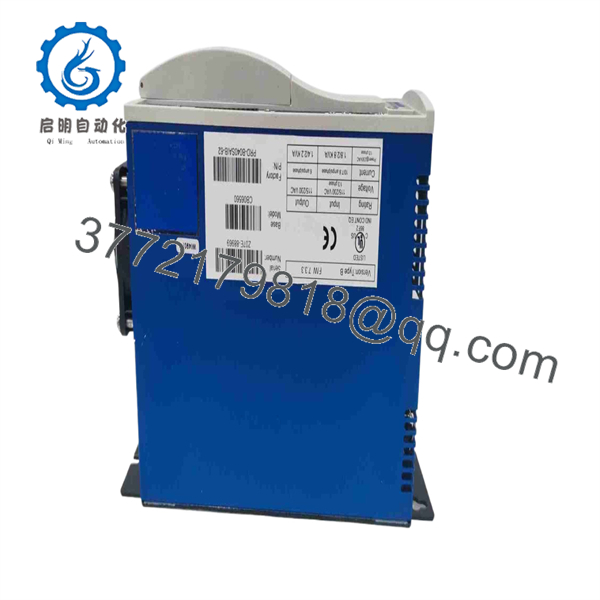
CB06560 PRD-B040SAIB-62
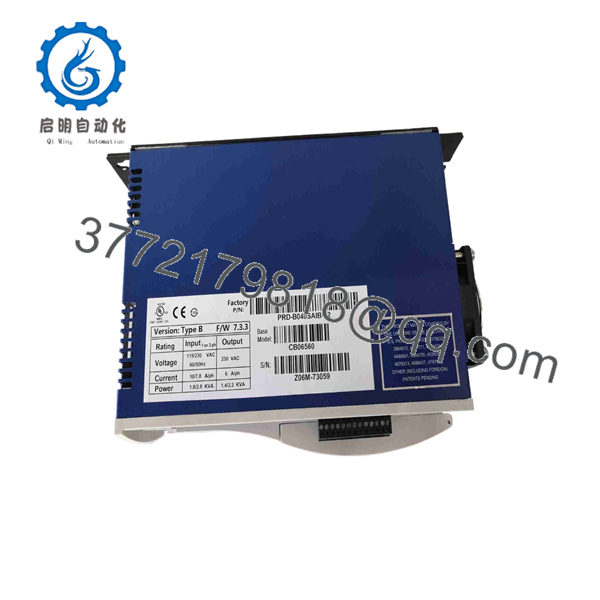
CB06560 PRD-B040SAIB-62
Frequently Asked Questions
Is CB06560 the same as PRD-B040SAIB-62?
CB06560 is commonly used as the Kollmorgen ordering or identification reference associated with the full PRD-B040SAIB-62 servo-drive designation. Match both identifiers when possible, then verify the drive revision, nameplate data, connector arrangement, feedback type, and installed application. A partial reference alone is not enough for a safe substitution.
Is this a direct replacement for every SERVOSTAR CD drive?
No. It is a direct replacement only when the existing drive is the same configuration or has been verified by documented Kollmorgen cross-reference data. Servo drives that share a similar housing can differ in continuous current, supply input, firmware, feedback interface, control interface, brake-output wiring, and motor parameter requirements.
What motor feedback does use?
Available distributor information identifies this model as a resolver-feedback drive. The cited resolver data includes a 0.47 transformation ratio, 7–8 kHz modulation frequency, 4.25 VAC drive excitation, maximum 120 Ω stator DC resistance, 55 mA AC RMS maximum excitation current, and 2 VAC resolver output to the drive. Confirm those values against the actual motor and OEM documentation before connecting a replacement drive.
Can I hot-swap this servo drive?
No. De-energize the machine and follow lockout/tagout procedures. Wait for the DC bus to discharge, verify safe voltage with correctly rated equipment, and only then disconnect the mains, motor, feedback, brake, and control wiring. Hot-swapping can damage the drive and connected equipment, and it creates a serious electrical and machine-motion hazard.
Will I lose programming when I replace the drive?
Possibly. The motor parameters, gain settings, limits, homing information, I/O assignments, and interface settings may reside in the servo drive, in a motion controller, or in both places. Save the parameter set from the working or failed drive whenever possible. Photograph all labels, connectors, jumper positions, and wiring before removal. To be honest, a legacy servo-drive swap becomes much harder when nobody preserved the original tuning file.
Why is a New Surplus cheaper than a factory-supplied drive?
New Surplus refers to unused inventory that entered the secondary market through excess stock, canceled projects, decommissioned systems, or inventory liquidation. It can be genuine unused stock, but it may not come through current factory distribution. Ask for actual-item photos, sealed-package evidence if applicable, date-code and revision photos, a written condition statement, functional test evidence, and warranty terms.
What testing should a supplier perform before shipping?
For a New Original / New Surplus unit, request inbound inspection, serial-label and packaging photos, visual inspection for storage damage, and confirmation that no rework marks or corrosion are present. For a Refurbished (tested) unit, request controlled power-up testing, fault-free status verification, I/O and command-interface checks, resolver-feedback validation, output testing with a suitable simulated motor load, thermal observation, and a documented test report. Public listing information identifies the model’s series, resolver interface, current-loop timing, and continuous current; it does not replace a unit-specific test record.