WhatsApp: +86 16626708626
 Email:
 Phone: +86 16626708626
Description
Key Technical Specifications
| Parameter | Value / Specification |
| Manufacturer | NSK (Nippon Seiko K.K., Japan) |
| Model Number | ESA-1010A35-21 |
| Product Family | Megatorque Motor Driver System |
| Main Power Input | Single-Phase 100–115 V AC (50/60 Hz) |
| Control Power Input | 100–115 V AC Control Power Rail |
| Peak Output Current | 10 A |
| Feedback Interface | Resolver / High-Precision Angle Sensor Input |
| Control Interfaces | RS-232C Serial (Handheld Terminal / PC) & Parallel I/O |
| Operating Environment | 0 to +50 °C (32 to 122 °F); 20–80% RH Non-Condensing |
| Cooling Method | Convection / Internal Heatsink |
| Mounting Orientation | Vertical Wall-Mount inside NEMA / IP20 Control Cabinet |
Product Introduction & Supply Chain Strategy
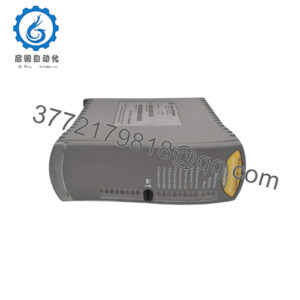
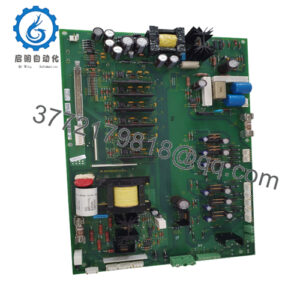
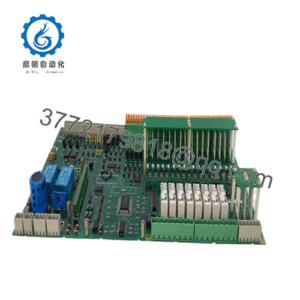
This product is a Brand New Surplus unit. It is not used, not pulled from a decommissioned plant, and not refurbished. All modules undergo rigorous quality verification to ensure OEM-level reliability. The NSK ESA-1010A35-21 is a high-precision digital servo driver built specifically to drive NSK Megatorque direct-drive gearless motors in rotary indexing tables, semiconductor handling systems, and robotics.
Maintaining this unit as New Surplus provides a crucial buffer against extended line shutdowns. Because NSK has discontinued several legacy Megatorque series drivers, an unexpected drive failure typically forces an expensive retrofitting process that requires replacing both motor and controller. Carrying a genuine, zero-wear ESA-1010A35-21 on-site eliminates lead time variability and dramatically lowers your total cost of ownership (TCO).
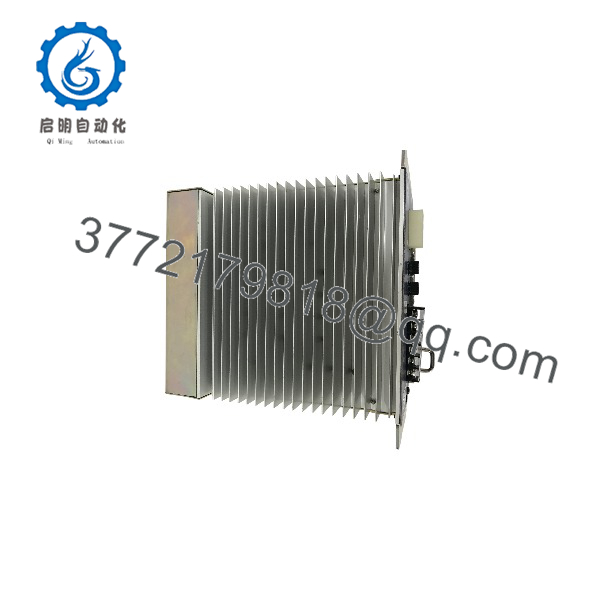
ESA-1010A35-21
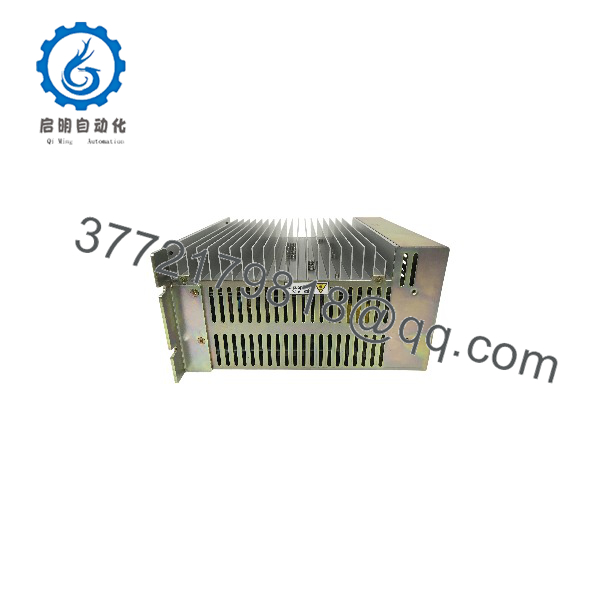
ESA-1010A35-21
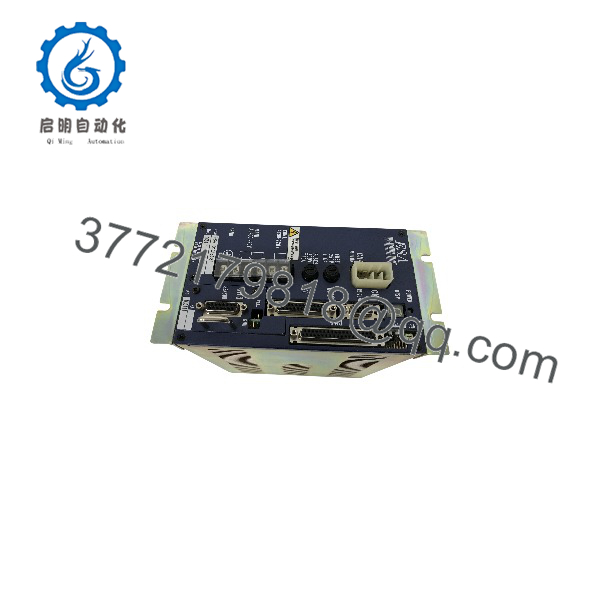
ESA-1010A35-21
Installation & Configuration Guide
Stage 1: Pre-Installation (Prep & Safety)
- De-energize the main control cabinet and perform Lock-Out/Tag-Out (LOTO) on the incoming 100–115 V AC lines.
- Put on an ESD-grounded wrist strap prior to opening the enclosure or handling terminal blocks.
- Document all DIP switch settings, jumper positions, and rotary node address switches on the front panel of the existing driver.
- Label all terminal block wiring harnesses, motor power connections, and feedback cables.
Stage 2: Removal
- Unplug the feedback sensor cable (Resolver) and RS-232C communication cable.
- Unfasten the screw terminals on the main AC input, motor output (U, V, W), and control I/O connectors.
- Loosen the upper and lower cabinet mounting bolts securing the drive backplate.
- Carefully lift the driver off the panel DIN/mounting rails, ensuring no thermal paste or metallic debris drops onto surrounding gear.
Stage 3: Installation (Clone & Seat)
- Set all DIP switches and jumpers on the new ESA-1010A35-21 unit to match the original unit exactly.
- Mount the driver vertically on the cabinet backplate, allowing at least 50 mm (2 inches) of free space above and below for natural convection cooling.
- Reattach the earth ground (PE) green/yellow cable securely to the driver’s chassis ground terminal.
- Reconnect the motor power leads (U, V, W), control I/O harness, and feedback cable to their designated ports.
Stage 4: Power-On & Testing
- Verify line voltage on the incoming power terminals reads between 100 and 115 V AC before applying power.
- Apply control power first. Check that the front-panel status LED displays the normal standby code (no alarm/fault flags).
- Enable drive output and test low-speed rotary indexing to confirm smooth rotation, correct direction, and absence of excessive motor hum or tracking errors.
Firmware/Software Versions & Upgrade Notes
- Parameter Retention: The ESA-1010A35-21 uses internal EEPROM memory to store motor parameter tables, gain profiles, and home positions. When swapping units, parameter files must be uploaded from the old drive or downloaded from backup via the NSKMegaterm software (or handheld terminal) over RS-232C.
- Firmware Compatibility: Ensure the suffix suffix code (
-21) matches your existing system parameters. Parameter maps from earlier board revisions (e.g.,-10or-11) may require parameter address translation during initialization. - Caution on Downgrading: Never attempt to flashing unverified firmware or loading parameter binaries built for different motor frame sizes, as incorrect commutation angles can result in immediate overcurrent trips or uncontrolled motor movement.
Frequently Asked Questions (FAQ)
Q: Is this NSK ESA-1010A35-21 unit brand new or refurbished?
A: This product is a Brand New Surplus unit. It is not used, not pulled from a decommissioned plant, and not refurbished. All modules undergo rigorous quality verification to ensure OEM-level reliability.
Q: Why is buying New Surplus better than opting for a cheap refurbished drive?
A: Refurbished drives frequently contain aged electrolytic bus capacitors, weakened optocouplers, and heat-stressed power transistors. A failure on a direct-drive indexing axis can cause mechanical collisions and thousands of dollars in lost production. New Surplus guarantees factory-fresh components with a full 10-15 year operational expectancy.
Q: Can I swap this unit directly without backing up parameters?
A: No. While the hardware matches directly, servo parameters (gain settings, acceleration curves, axis address) are stored in the driver’s non-volatile memory. You must load your machine’s parameter file into the new using NSK software or a handheld terminal before running the axis.
Q: What is the primary cause of damage to these Megatorque drivers?
A: The most common failure modes are incoming AC line surges, improper grounding causing resolver feedback noise, and overheating due to blocked cabinet airflow or failed cooling fans.
Q: What warranty coverage comes with this replacement driver?
A: We provide a full 1-year functional warranty on this unit. Every drive is serialized, electrically verified, and shipped in heavy-duty ESD-safe protective packaging.